Explainers
Whole-Body Control: How Humanoids Coordinate Arms, Legs, and Balance
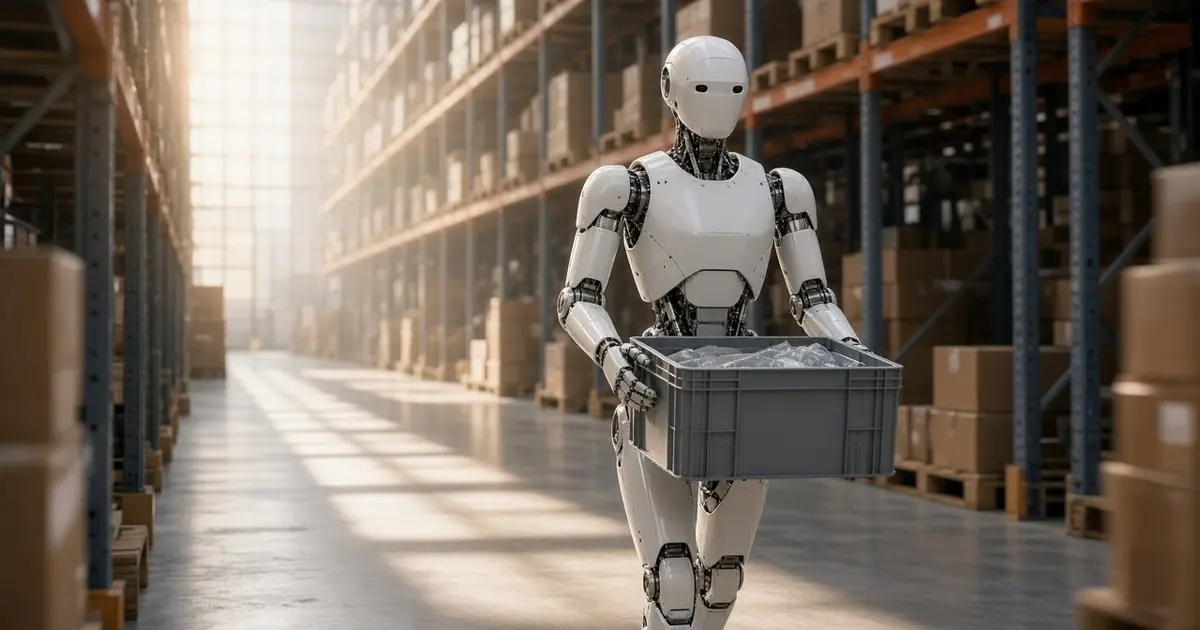
A humanoid carrying a box cannot control its arms independently of its legs. The load changes how the body must balance, and a step changes the ground contacts available to support it. Whole-body control is the approach of coordinating the robot's many joints and contacts as one coupled system, rather than treating every limb as an isolated machine.
One body, competing objectives
A humanoid may need to keep its feet in contact with the floor, maintain its torso orientation, move a hand toward a target, and avoid exceeding actuator limits, all at the same time. Those goals can conflict. Reaching farther may require leaning; leaning changes the required support forces; preserving balance may require reducing the reach or taking a step.
MIT's Underactuated Robotics notes frame highly articulated legged robots around center-of-mass dynamics, contact forces, footstep planning, and whole-body control. The crucial idea is that an instruction such as “move the hand here” is incomplete. The controller also needs to know what the feet are doing and which body motions are physically feasible while the hand moves.
A conventional arm bolted to the floor has a fixed base. A walking humanoid has a floating base: its torso is not attached to the world by a rigid joint. Its feet temporarily provide the support. As contacts are made and broken, the equations and allowable motions change. This makes a coordinated controller especially important during walking and manipulation at the same time.
Tasks are often written in operational space
A controller can specify an objective in terms of a hand position, torso orientation, center-of-mass motion, or foot contact rather than prescribing every joint angle in advance. The robot's kinematics relate these task-space goals to the joints. But multiple sets of joint motions may satisfy the same hand movement, and some may be much safer or easier than others.
Whole-body methods use the remaining freedom to satisfy additional objectives. For example, the hand can move toward a shelf while the torso stays approximately upright and the stance foot remains fixed. If the task becomes infeasible, the controller needs a rule for which objective takes precedence. A sensible priority structure might preserve hard physical and safety constraints before optimizing the accuracy of a reach.
Why optimization appears so often
Kim and colleagues describe prioritized whole-body controllers that incorporate centroidal momentum dynamics, task priorities, contact reaction forces, and internal-force constraints. Their 2018 research uses quadratic programming and discusses friction-cone constraints and smooth contact transitions. A quadratic program selects control variables that best satisfy an objective while obeying stated constraints.
This is not magic optimization that makes every requested movement possible. If a foot lacks enough friction, no numerical solver can create it. If a joint has reached its limit, a controller must change the requested motion or redistribute the task. The value of the optimization formulation is that those conflicts can be represented explicitly rather than hidden in separate limb commands.
A useful mental model is a robot holding a crate while stepping sideways. The controller has to allocate joint effort between maintaining the crate's pose and controlling the center of mass. It must also keep the supporting foot from sliding and prepare the next foot contact. Solving only the hand trajectory would omit most of the problem.
Contacts can be tools, not just obstacles
A robot can use its environment to stabilize itself. Rouxel, Ivaldi, and Mouret describe a whole-body force-control approach for position-controlled robots that supports multiple contacts, such as a hand against a wall or handrail. Their SEIKO pipeline uses two quadratic programs and was evaluated on the full-scale Talos humanoid in tasks including pushing, reaching, stair climbing, and sloped-surface stepping.
That work highlights a subtle distinction. A robot that can command joint positions does not necessarily have direct control of contact forces. The researchers address this through an explicit flexibility model and optimization. A hand resting on a wall is not simply another position target: the force transmitted through that contact affects balance and must be accounted for.
Safety constraints belong inside the motion problem
Paredes and Hereid propose a whole-body task-space controller with constraints involving the zero-moment point, friction cone, and torque, along with additional safety conditions. They report experiments involving the Digit biped. The broader lesson is that posture and balance are not afterthoughts to be checked only after a movement has been generated. They can be integrated into the calculation that generates movement.
Still, a research controller demonstrated in one setup should not be mistaken for universal reliability. Results depend on the robot's actuation, contact model, sensing, and task conditions. An evaluator should ask which constraints are hard, which are soft, what happens when objectives conflict, and whether the robot can recover from unexpected contact.
Whole-body control is therefore best understood as an allocation problem: distribute limited motion and force capability across the entire robot while keeping the current contacts and intended task consistent. It is the coordination layer that makes walking while working a coherent engineering objective rather than two unrelated demonstrations.